Moball
2016
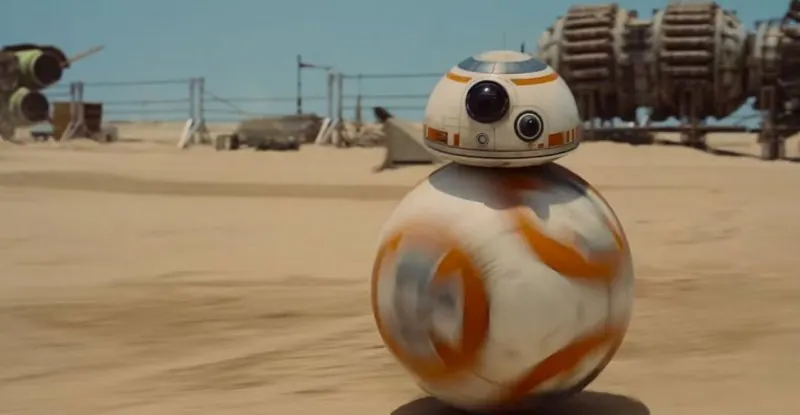
We aim to create a spherical robot cabable of maneuvering around the Mobot course
We plan to start out with a passive system that will use an actuated weight to alter its path down a hill. We hope to do this using a servo as a pendulum or on a rail/linear gear in a 3D printed shell. After this, we hope to implement a path-planning system to enable the robot to traverse a course.
Team
- @hlyness
- @iem
- @mlongo